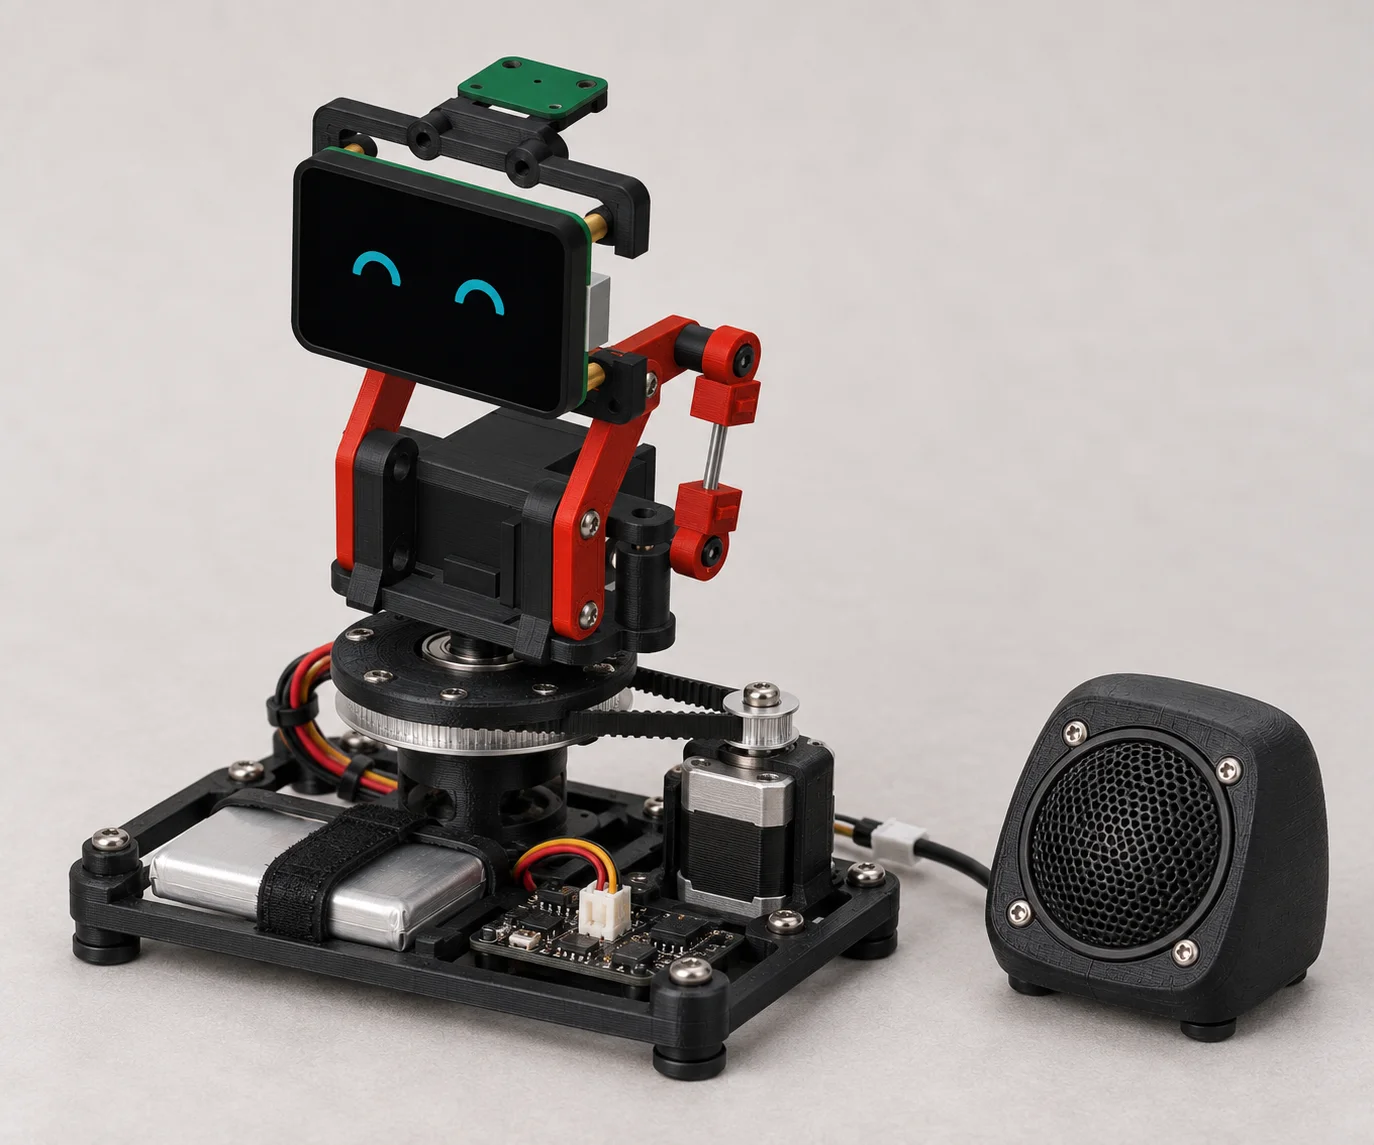
Remove the tall drive structure
The new direction swaps the gantry for a small ungeared stepper with a pulley right on its shaft. A short toothed belt drives a larger pulley under a bearing-supported platform. The aim is a low, open structure that keeps the existing tilt mechanism wherever practical.
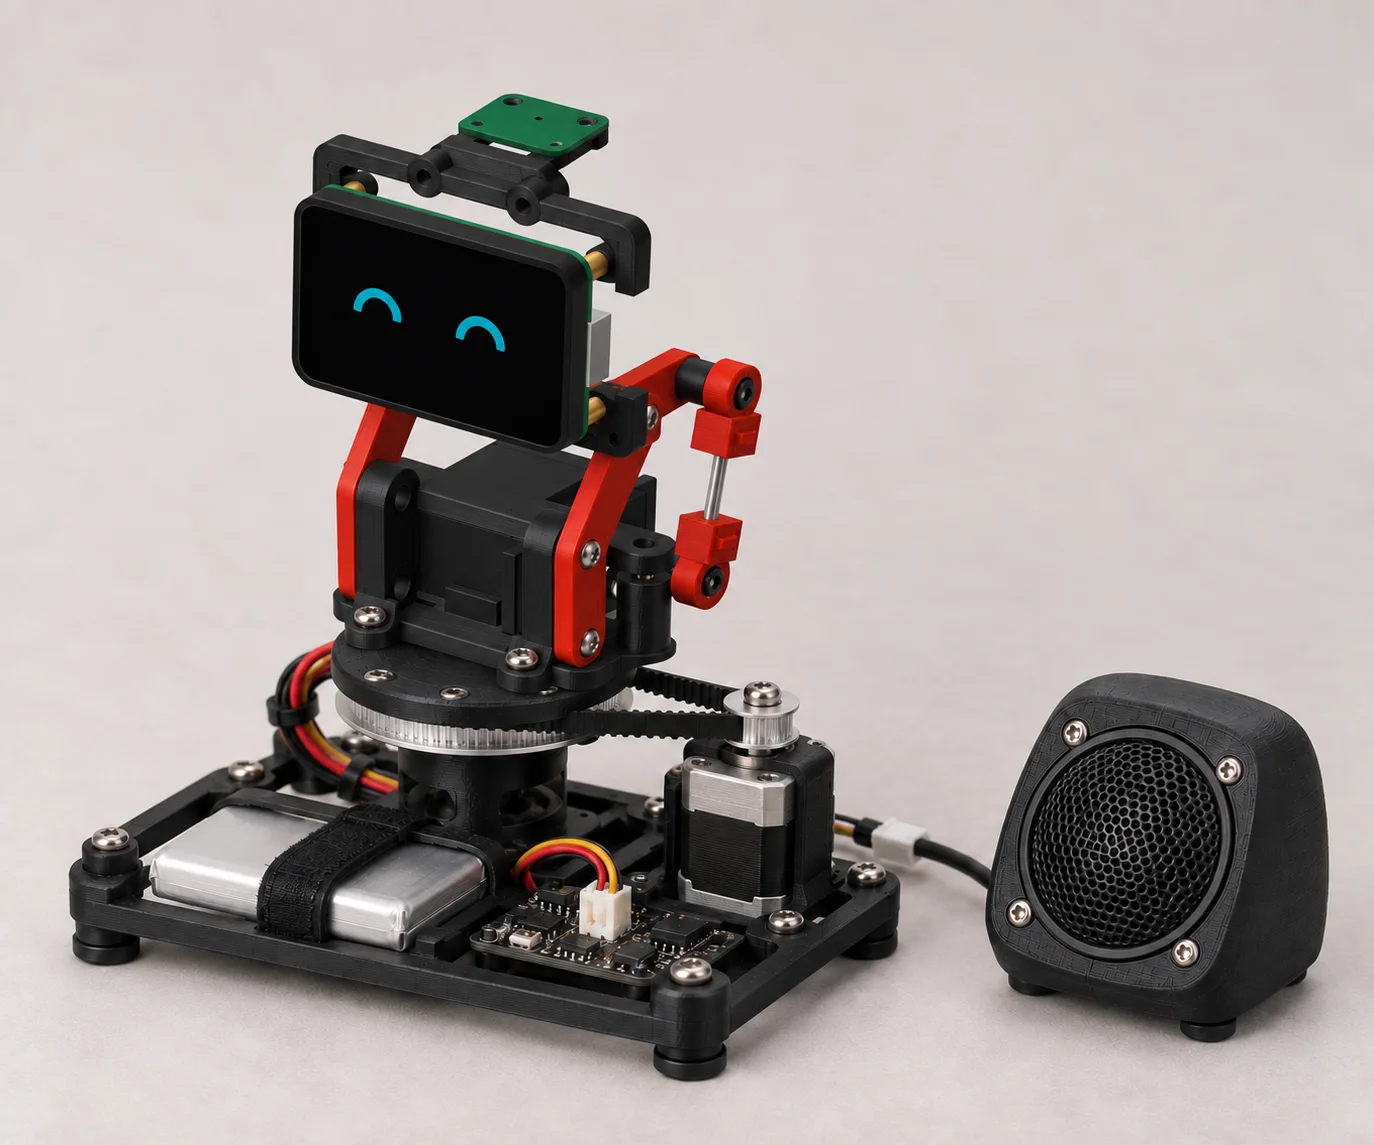
Put the carriage on the disk
The second mockup drops the raised connection from the first image and sets the tilt carriage directly on the broad rotating disk, with the bearing support underneath. It shows the arrangement I'm aiming for, not dimensioned mounting geometry.
Let the speaker be optional
The big speaker moves out into its own plug-in enclosure. The desk robot shouldn't need that pod, the optional shell panels, or a future mobile chassis in order to work. Those interfaces are still design work, not finished interchangeable modules.
Select hardware before fixing dimensions
The brief weighs a small stepper, a reduction belt drive, a suitable driver, and a repeatable home reference. Choosing the exact hardware, then checking shaft loading, missed steps, and structure, comes before any new mounting geometry. There is no print-ready stepper release in this chapter.